Radiomaster Nexus
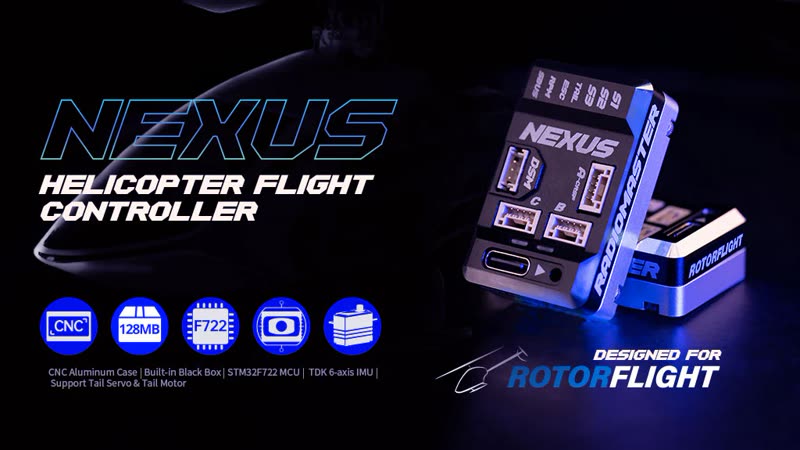
| Board | NEXUS_F7 |
| MCU | STM32F722RET6 |
| Gyro | ICM-42688-P |
| Blackbox | 128 MB flash |
| Barometer | SPL06-001 |
| Servo outputs | S1, S2, S3, TAIL |
| Motor output | ESC; tail motor supported |
| RPM input | RPM (from the ESC or a sensor) |
| UARTs | DSM (UART1), S.BUS (UART2), A-CRSF (UART4), Port B (UART6), Port C (UART3) |
| Supply | 5-12.6 V |
| Port power | Ports A, B, C: 5 V, 2 A. DSM: 3.3 V, 0.5 A |
| Size, weight | 41.3 × 25.4 × 13.1 mm, 16.8 g |
Wiring
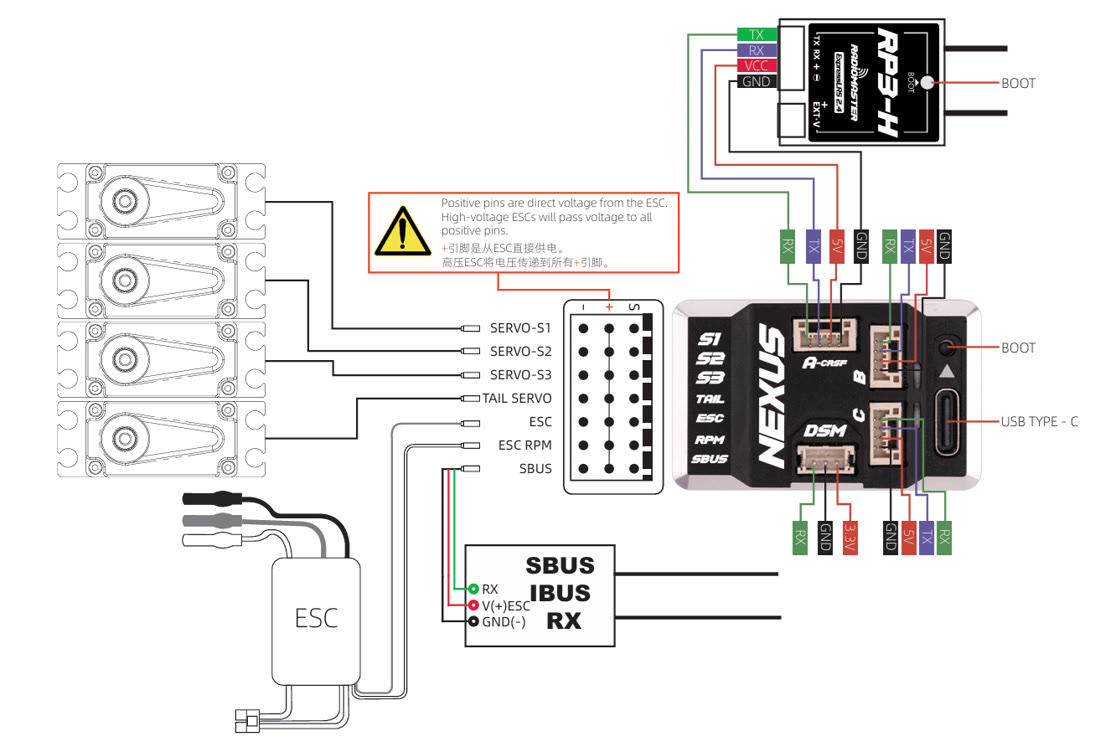
Servo rail voltage
The + pins on the servo header carry the ESC's BEC voltage directly. A high-voltage BEC puts that voltage on every + pin -- make sure everything plugged in can take it.
Port A is set up for an ExpressLRS/CRSF receiver; Radiomaster's RP3-H plugs straight in. The ports are labelled in the Configurator with their board names (Port A, S.BUS, DSM...), so pick the function for each on the Configuration tab.
F.Port works on the TX pin of Port A, B or C, with Inverted and Half-Duplex on in the Receiver tab.
Motorised tail
Turn the TAIL servo output into a tail motor output:
resource SERVO 4 NONE
resource MOTOR 2 B03
save
Or use the Remap FC tab (2.4).
Nexus X and Nexus XR
The Nexus X (NEXUS_X) and Nexus XR (NEXUS_XR) are the
second-generation Nexus, with the servo header in the order S1, S2, S3,
TAIL, ESC, RPM, TLM, AUX, SBUS. The XR adds a built-in ExpressLRS
receiver, on UART5.
Motorised tail on the X and XR:
resource SERVO 4 NONE
resource MOTOR 2 A15
save