Flywing HELI405
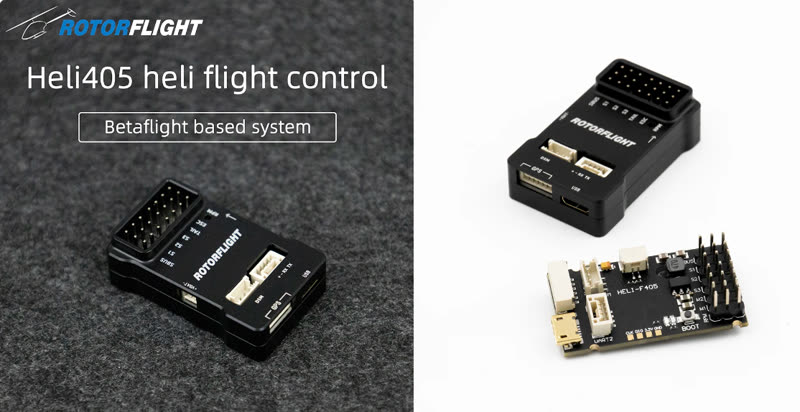
| Board | FLYWING_HELI405 for a servo tail; FLYWING_HELI405M for a motorised tail |
| MCU | STM32F405RGT6 |
| Gyro | ICM-42688 |
| Blackbox | 16 MB |
| Barometer | SPL06 |
| Servo outputs | CH1-CH4 |
| RPM input | RPM (ESC RPM wire) |
| UARTs | UART1 GPS connector; UART2 top JST-GH port and SBUS; UART6 DSM |
| Voltage input | VBat 5-30 V |
| BEC input | 5-19 V |
| USB | Micro USB |
| Size, weight | 42 × 22 × 14 mm, 17 g |
Pick the board for your tail type when flashing: the M version has the
tail output set up as a motor.
Wiring
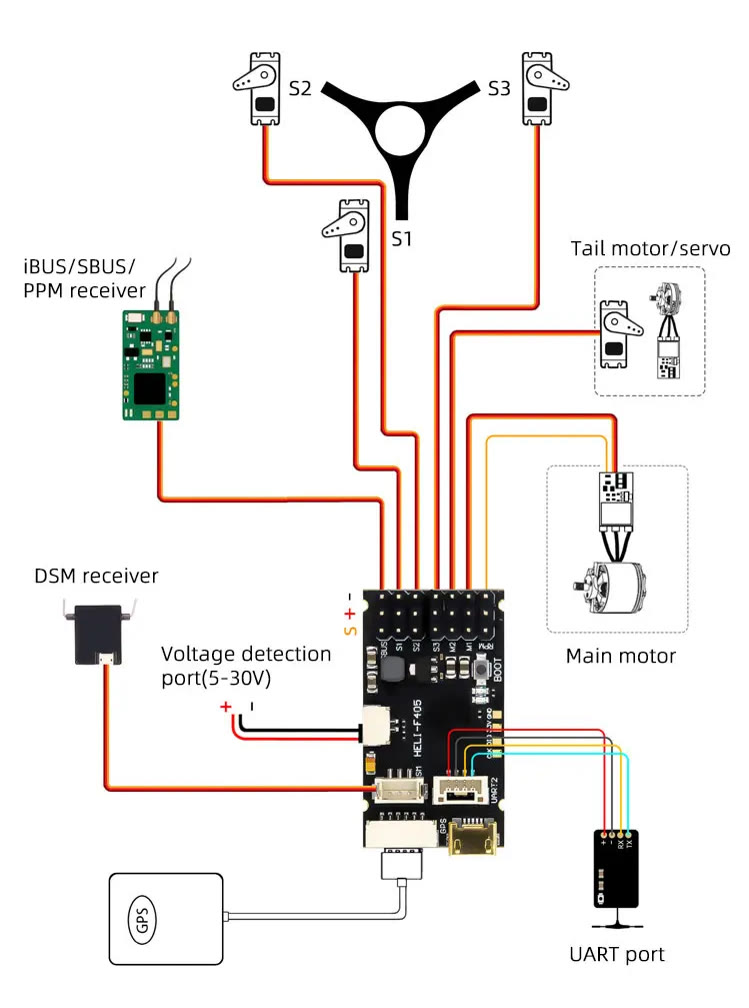
The main connector carries SBUS, S1-S3, TAIL, ESC and RPM. The DSM connector (UART6) is receive-only, for a Spektrum satellite.
As an F405, the HELI405 can't invert or pin-swap its UARTs in software -- see Receiver.
To use the SBUS pin for an LED strip, see LED Strip.