GPS
Settings and live status for a GPS module. In Rotorflight, GPS is used for telemetry -- position, speed, altitude and distance on your radio -- and for flight statistics.
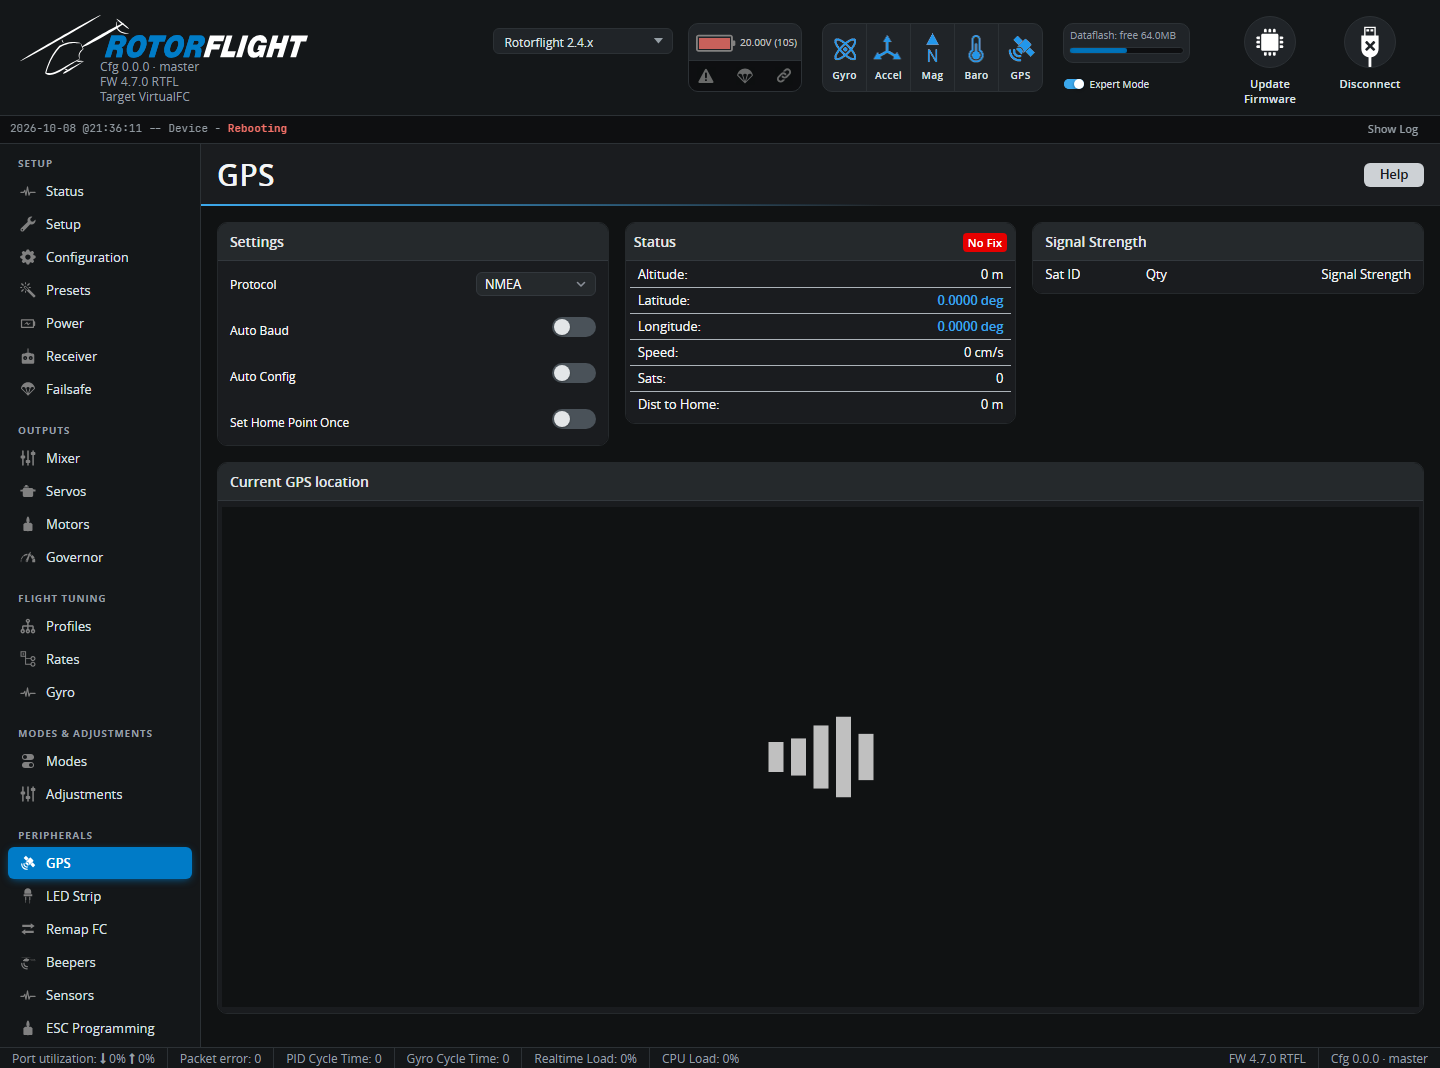
The tab appears once the GPS feature is on and a UART is set to GPS on the Configuration tab.
Settings
| Setting | |
|---|---|
| Protocol | UBLOX for u-blox modules (most GPS modules), or NMEA. |
| Ground Assistance Type | SBAS correction: Auto-detect, or pick your region (EGNOS, WAAS, MSAS, GAGAN), or None. |
| Auto Baud | Finds the module's baud rate automatically. |
| Auto Config | Configures a u-blox module for the flight controller at power-up. Leave it on. |
| Use Galileo | Use the European Galileo satellites (instead of the Japanese QZSS). |
| Set Home Point Once | Use the first arming after power-up as home; otherwise home is reset on every arming. |
Status
Fix, number of satellites, position, altitude, speed and distance from home, with the signal strength of each satellite and the position on a map (the map needs an internet connection).