FlyDragon
FlyDragon F722 V2.2
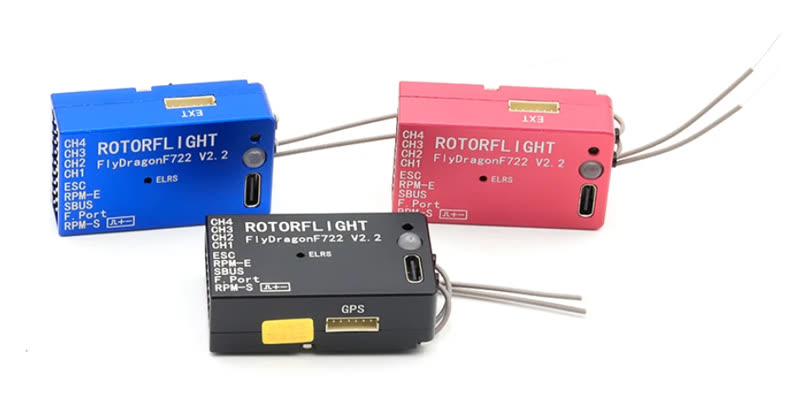
| Board | FLYDRAGON_V2_2 (older: FLYDRAGON_V2, FLYDRAGON_V1) |
| MCU | STM32F722RET6 |
| Gyro | BMI270 |
| Blackbox | 128 MB flash (W25N01G) |
| Barometer | SPL06 |
| Servo outputs | CH1-CH4 |
| RPM inputs | RPM-E (ESC RPM wire), RPM-S (separate RPM sensor) |
| UARTs | UART1 internal receiver; UART2 SBUS/F.Port connector; UART3 extension port; UART5 GPS port |
| Built-in receiver | ExpressLRS 2.4 GHz diversity, on UART1 |
| Other | WS2812 LED, 5 V buzzer, USB-C |
| BEC input | 5-15 V; 5 V output 1.5 A |
| Size, weight | 45 × 27 × 14.5 mm, 27 g |
Wiring
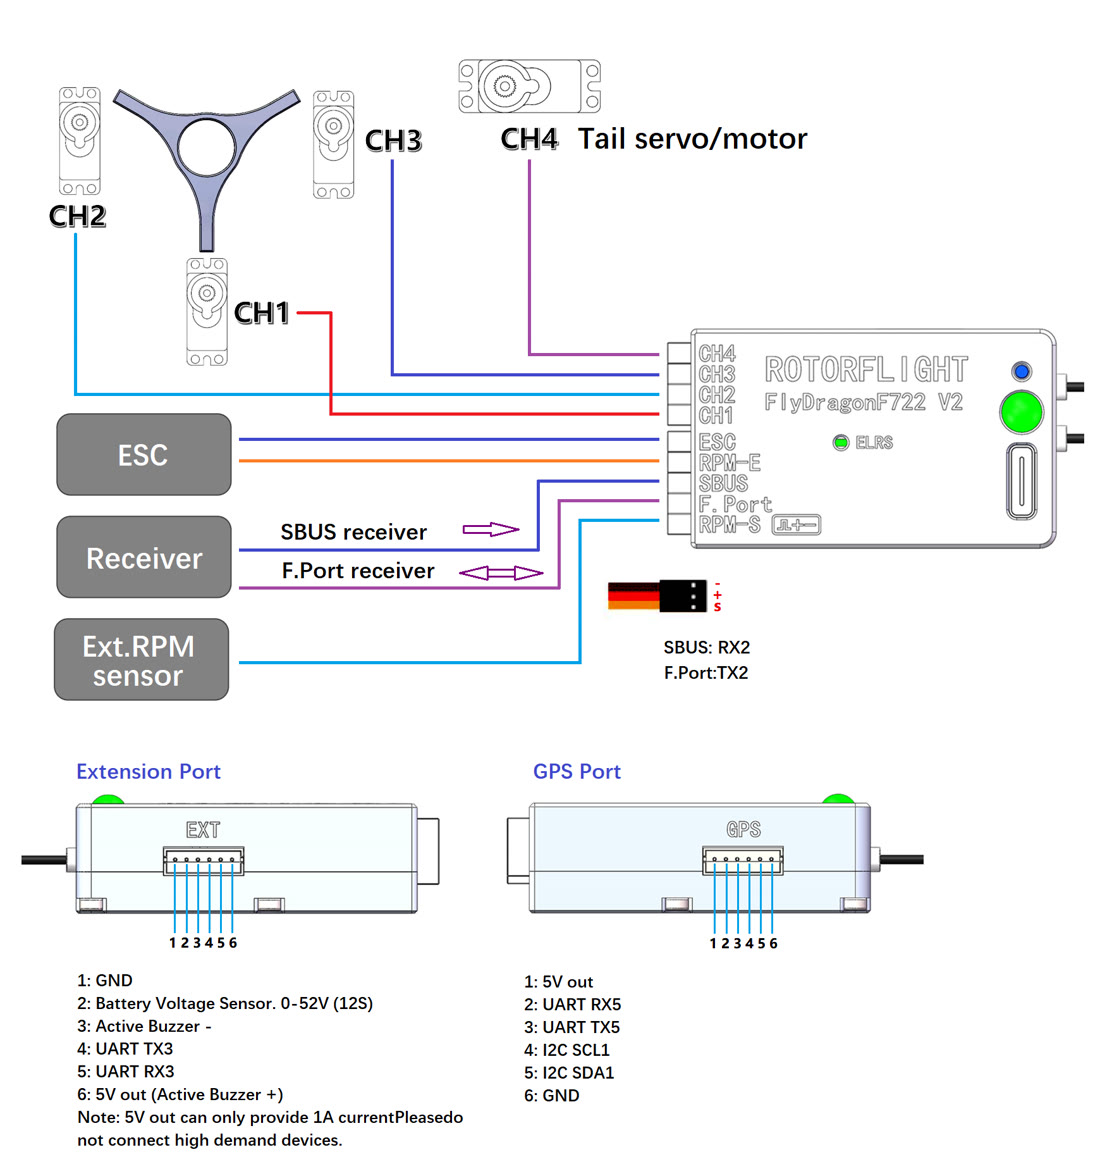
RPM-S power
The RPM-S port is powered from the board's internal 5 V supply, which is also live on USB. Don't connect anything that supplies power to it -- such as an ESC's BEC lead.
Internal receiver
The built-in ELRS receiver is on by default. To use an external receiver (on SBUS, F.Port, UART3 or UART5), switch it off in the CLI:
set pinio_config = 1,1,1,1     # internal receiver off
set pinio_config = 129,1,1,1   # internal receiver on
save
RPM inputs
resource FREQ 1 A01 # RPM-E for the main motor (default)
resource FREQ 1 A15 # RPM-S for the main motor
resource FREQ 1 A01      # RPM-E: main motor
resource FREQ 2 A15      # RPM-S: tail motor
Follow each with save.
Motorised tail
resource SERVO 4 NONE
resource MOTOR 2 C09
save
Extra servo on SBUS or F.Port
SBUS pin as servo 5, driven by channel 10:
resource SERIAL_RX 2 NONE
resource SERVO 5 A03
timer A03 AF3
mixer input CH10 -1000 1000 1000
mixer rule 10 set CH10 S5 1000 0
save
For the F.Port pin instead, use SERIAL_TX 2 and pin A02. See also
Adding an extra servo.
Manuals
FlyDragon PRO
The FlyDragon PRO comes in two gyro versions -- choose the board matching
yours: FLYDRAGON_PRO42688 (ICM-42688-P) or FLYDRAGON_PRO6000. Its rear
connector carries ESC, RPM, TAIL, CH1-3, TX2/RX2 and AUX; the internal ELRS
receiver is on UART1.
Motorised tail: TAIL (C09) can become motor 2 in the same way as the V2.2, or with the Remap FC tab.